Self-Tuning PID Control via a Hybrid Actor-Critic-Based Neural Structure for Quadcopter Control
30th Annual International Conference of Iranian Society of Mechanical Engineers (ISME)
Cite this paper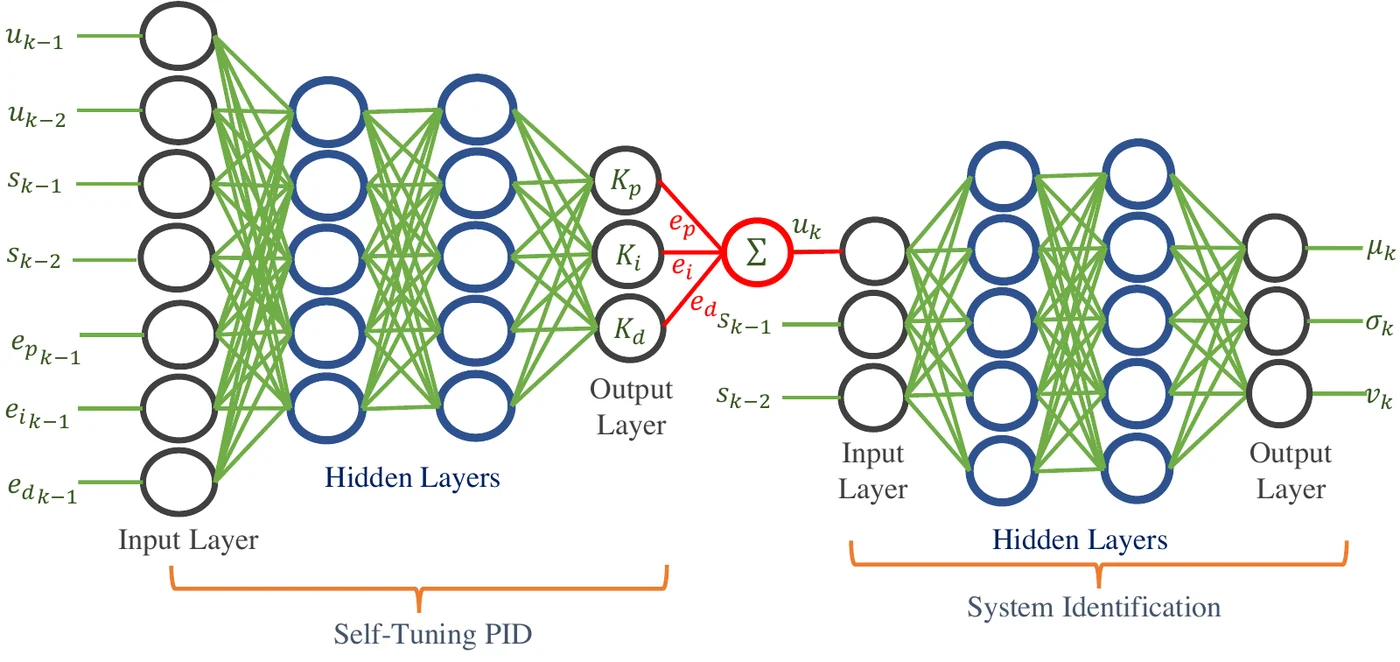
Abstract
Proportional-Integrator-Derivative (PID) controller is used in a wide range of industrial and experimental processes. There are a couple of offline methods for tuning PID gains. However, due to the uncertainty of model parameters and external disturbances, real systems such as Quadrotors need more robust and reliable PID controllers. In this research, a self-tuning PID controller using a Reinforcement-Learning-based Neural Network for attitude and altitude control of a Quadrotor has been investigated. An Incremental PID, which contains static and dynamic gains, has been considered and only the variable gains have been tuned. To tune dynamic gains, a model-free actor-critic-based hybrid neural structure was used that was able to properly tune PID gains, and also has done the best as an identifier. In both tunning and identification tasks, a Neural Network with two hidden layers and sigmoid activation functions has been learned using Adaptive Momentum (ADAM) optimizer and Back-Propagation (BP) algorithm. This method is online, able to tackle disturbance, and fast in training. In addition to robustness to mass uncertainty and wind gust disturbance, results showed that the proposed method had a better performance when compared to a PID controller with constant gains.
Cite
I. Sharifi and A. Alasty. (2022). "Self-Tuning PID Control via a Hybrid Actor-Critic-Based Neural Structure for Quadcopter Control." ISME Conference, 2022.
@inproceedings{sharifi2022selftuning,
  title     = {Self-Tuning PID Control via a Hybrid Actor-Critic-Based Neural Structure for Quadcopter Control},
  author    = {Sharifi, Iman and Alasty, Aria},
  booktitle = {30th Annual International Conference of the Iranian Society of Mechanical Engineers (ISME)},
  year      = {2022},
  eprint    = {2307.01312},
  archivePrefix = {arXiv}
}